Reference Frame
R2026bNon-inertial reference frame
Reference Frame block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Simscape /
Multibody /
Frames and Transforms
Description
This block represents a reference frame with respect to which you can define other frames. The reference frame is generally non-inertial. It can accelerate with respect to the World frame. This block is optional in a model.
Examples
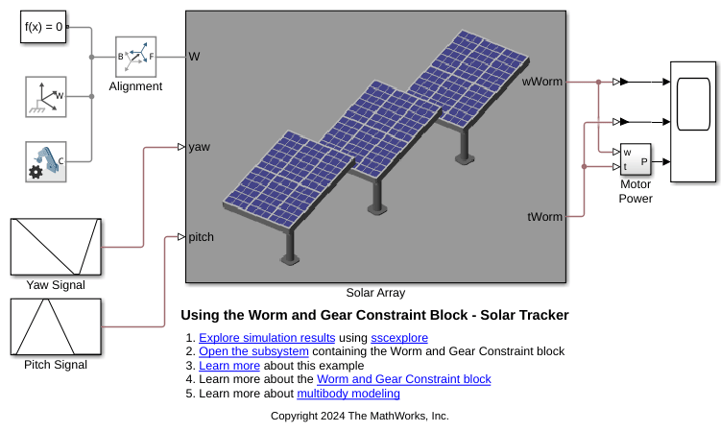
Using the Worm and Gear Constraint Block - Solar Tracker
Illustrates the use of the Worm and Gear Constraint block to model a solar tracker. A slew drive containing a worm and gear constraint powers the yaw rotation of the solar trackers. The worm and gear geometry gives a large reduction in a single stage of gearing which provides precision tracking and high torque output. The yaw rotation is specified as a motion input to the gear revolute joint and the necessary actuator torque is automatically computed at the worm revolute joint.
Ports
Frame
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"sm_lib/Frames and Transforms/Reference Frame"
Example: add_block("sm_lib/Frames and Transforms/Reference Frame","myModel/myBlock",MakeNameUnique="on")
Extended Capabilities
Version History
Introduced in R2012a

