cylinderModel
R2026bObject for storing parametric cylinder model
Description
The cylinderModel object stores the parameters of a parametric
cylinder model. After you create a cylinderModel object, you can extract
cylinder surface points and points within the cylinder using the object functions. Cylinder
models are used to store the output of the pcfitcylinder function, which fits a cylinder over a point cloud.
Creation
There are two ways to create a cylinderModel object.
Create a cylinder model by specifying the cylinder parameters in the
cylinderModelobject.Fit a cylinder model over a point cloud using the
pcfitcylinderfunction.
Description
model = cylinderModel(parameters)parameters.
The parameters argument is a 1-by-7 numeric vector that determines
the value of the Parameters property.
Input Arguments
Properties
Object Functions
plot | Plot parametric model |
findPointsInModel | Find points in or on surface of geometric model |
transform | Transform geometric models between coordinate frames |
Examples
Load a MAT file containing a point cloud into the workspace.
load("object3d.mat");Display the point cloud.
figure
pcshow(ptCloud)
title("Detect a Cylinder in a Point Cloud")
Set the maximum point-to-cylinder distance for cylinder fitting to 5mm.
maxDistance = 0.005;
Specify a region of interest (ROI) to constrain the fitting function.
roi = [0.4 0.6; -inf 0.2; 0.1 inf];
sampleIndices = findPointsInROI(ptCloud,roi);
Set the orientation constraint for the fitting function
referenceVector = [0 0 1];
Detect the cylinder in the specified ROI of the point cloud and extract it.
model = pcfitcylinder(ptCloud,maxDistance,referenceVector, ...
        SampleIndices=sampleIndices);
Plot the model of the detected cylinder.
hold on
plot(model)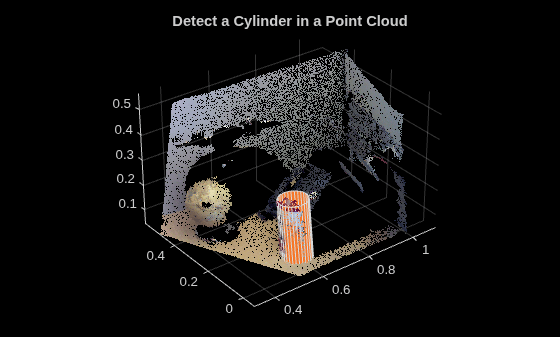
Version History
Introduced in R2015bSee Also
Objects
pointCloud|planeModel|sphereModel|cuboidModel|rigidtform3d(Image Processing Toolbox)
Functions
pcfitcylinder|pcfitplane|pcfitsphere|pcfitcuboidalign|pcfitcuboid|pcshow|pcplayer|pcwrite|pcread|pcmerge|pctransform|pcdownsample|pcdenoise|pcregistericp
Topics
- 3-D Point Cloud Registration and Stitching (Computer Vision Toolbox)

