Differential Drive Kinematic Model
R2026bCompute vehicle motion using differential drive kinematic model
Differential Drive Kinematic Model block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Robotics System Toolbox /
Mobile Robot Algorithms
Description
The Differential Drive Kinematic Model block creates a differential-drive
vehicle model to simulate simplified vehicle dynamics. This model approximates a vehicle with
a single fixed axle and wheels separated by a specified track width Track width.
Each of the wheels can be driven independently using speed inputs, dϕL/dt and dϕR/dt, for the left and right wheels respectively.
Vehicle speed and heading is defined from the axle center.

Examples
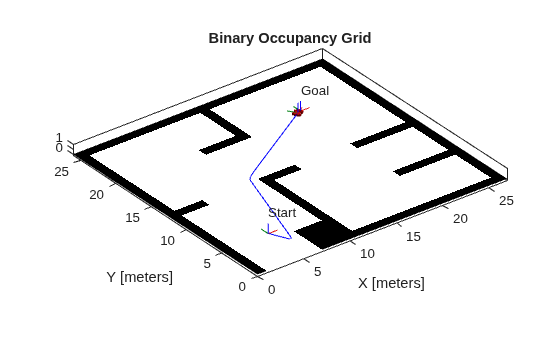
Plan Path for a Differential Drive Robot in Simulink
Navigate a differential drive robot on an obstacle-free path in Simulink® using probabilistic roadmap (PRM) planning and Pure Pursuit control.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"robotmobilelib/Differential Drive Kinematic Model"
Example: add_block("robotmobilelib/Differential Drive Kinematic Model","myModel/myBlock",MakeNameUnique="on")
References
[1] Lynch, Kevin M., and Frank C. Park. Modern Robotics: Mechanics, Planning, and Control 1st ed. Cambridge, MA: Cambridge University Press, 2017.
Extended Capabilities
Version History
Introduced in R2019b

