CAN Vendor
R2026bSpecify CAN vendor
Since R2026b
Model Configuration Pane: Hardware Implementation / Hardware board settings / Target hardware resources / Connectivity
Description
Specify CAN vendor for universal measurement and calibration protocol (XCP) over CAN through which the host computer communicates with the target hardware for external mode simulation.
Dependencies
To enable this parameter, set Communication interface to
CAN and Connectivity interface parameter
to CAN (MCAN. The value of
x)x depends on the
Device
Series parameter value.
Settings
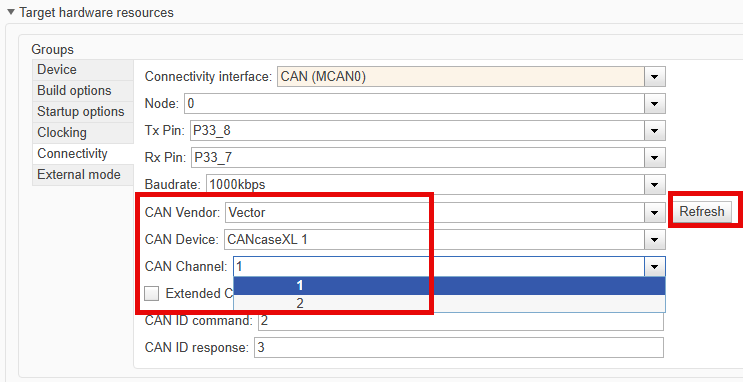
<empty> (default) | options vary depending on the CAN interface device connectedEnsure that you connect the CAN interface device to the hardware board before selecting a vendor. Click the Refresh button to view the available CAN vendor options. If no vendors appear, verify that the hardware drivers are installed correctly and that the hardware is compatible with your MATLAB® and Simulink® version.
CAN Device and CAN Channel parameter values will appear after you select a value for the CAN Vendor parameter. For example, the screenshot shows the configuration settings for Vector CAN interface device.
Recommended Settings
No recommendation.
Programmatic Use
| No programmatic use is available. |
Version History
Introduced in R2026b

