Multibody Dynamics
R2026bMultibody dynamics is the study of the dynamic behaviors of mechanical systems that consist of rigid and/or flexible bodies connected by joints. The bodies undergo translational and rotational motions caused by applied forces, torques, and constraints. Simscape™ Multibody™ enables you to perform multibody dynamics simulations for complex systems, such as robots, vehicles, construction equipment, or aircraft landing gear. You can specify force, torque, and motion inputs to drive your model and simulate the dynamic responses of the model.
To specify the degrees of freedom between a pair of bodies, use blocks in the Joints and Constraints libraries. For example, you can use the Prismatic Joint block and Revolute Joint block to model the straight-line and rotary motions of a slider-crank mechanism. You can use the Point on Curve Constraint block to model the constraint between a roller coaster car and the track.
To model forces and torques that act on bodies, use blocks in the Forces and Torques library. For example, you can use the Magic Formula Tire Force and Torque block to model the tire forces and torques between a tire and ground surface. When modeling contact problems, such as robotic grasping, you can use the Spatial Contact Force block to simulate forces between a pair of bodies.
To measure the relative motions between bodies, you can use the Transform Sensor block. To measure forces and torques, you can use blocks in the Constraints, Joints, and Forces and Torques libraries. The loads on the bodies at the joints can be measured at the joint blocks, and a constraint block can sense the forces and torques that maintain the constraint between a pair of bodies. Each of these quantities help you answer important questions as you analyze the multibody dynamics of the mechanical system.
Classes
Simscape Blocks
 | Angle Constraint | Fixed angle between two frame Z axes |
 | Distance Constraint | Fixed distance between two frame origins |
 | Point on Curve Constraint | Kinematic constraint between frame origin and curved path |
 | Point on Surface Constraint | Kinematic constraint between frame origin and 2-D surface |
Joints with One or No Primitives
 | Prismatic Joint | Joint that allows relative motion along single axis |
 | Revolute Joint | Joint with one revolute primitive |
 | Spherical Joint | Joint allows 3-D rotations |
 | Weld Joint | Joint with zero primitives |
Joints with Multiple Primitives
 | Bearing Joint | Joint with one prismatic and three revolute primitives |
 | Bushing Joint | Joint with three prismatic and three revolute primitives |
 | Cartesian Joint | Joint with three prismatic primitives |
 | Cylindrical Joint | Joint with one rotational and one translational degree of freedom |
 | Gimbal Joint | Joint with three revolute primitives |
 | Pin Slot Joint | Joint with orthogonal prismatic and revolute primitives |
 | Planar Joint | Joint with one rotational and two translational degrees of freedom |
 | Rectangular Joint | Joint with two prismatic primitives |
 | 6-DOF Joint | Joint with six degrees of freedom and no kinematic singularity |
 | Telescoping Joint | Joint with one spherical and one prismatic joint primitive |
 | Universal Joint | Joint that allows for transfer of rotary motion between unaligned shafts |
Joints with Coupled Degrees of Freedom
 | Constant Velocity Joint | Joint that enforces a constant-velocity kinematic constraint between two shafts |
 | Lead Screw Joint | Joint with coupled rotational and translational degrees of freedom |
 | Custom Tire Force and Torque | Compute interactions and spatial relationships between tire and ground surface (Since R2024a) |
 | External Force and Torque | Apply external force and/or torque to connected frame |
 | Gravitational Field | Model gravitational field |
 | Internal Force | General force acting reciprocally between two frame origins |
 | Inverse Square Law Force | Force proportional to the inverse square distance between two frame origins |
 | Magic Formula Tire Force and Torque | Apply steady-state tire force and torque by using Magic Formula tire equations |
 | Planar Contact Force | Model planar contact between two geometries (Since R2023b) |
 | Spatial Contact Force | Model spatial contact between two geometries |
 | Spring and Damper Force | Force proportional to the distance and relative velocity between two frame origins |
 | Inertia Sensor | Sensor to measure the inertial properties of body groups or mechanisms |
 | Transform Sensor | Sensor that measures the relative spatial relationship between two frames |
 | Mechanism Configuration | Mechanism-wide gravity and simulation parameters |
Topics
Sense Force, Torque, and Motion Outputs
- Analyze Motion at Various Parameter Values
Simulate a four-bar model at different coupler link lengths and plot the resulting coupler curves. - Sensing
Dynamic variables that you can sense and blocks that you can use to sense them. - Sense Motion Using a Transform Sensor Block
Use the Transform Sensor block to sense frame motion in a simple multibody model. - Measure Joint Constraint Forces
Use the sensing capability of a joint block to sense the internal forces acting on a mechanical link. - Measure Forces and Torques Acting at Joints
Use the sensing capability of joint blocks to measure the forces and torques acting at a joint.
Prescribe Force, Torque, and Motion Inputs
- Modeling Contact Force Between Two Solids
Use the Spatial Contact Force block to model normal and frictional forces between solid blocks. - Solid Cylinder Rolling Down an Incline
Use the Spatial Contact Force block to model the solid cylinder rolling down a ramp. - Model Gravity in a Planetary System
Assemble a system of gravitationally-bound free bodies using Cartesian Joint and Gravitational Field blocks. - Specify Joint Motion in Planar Manipulator Model
Use the actuation capability of joint blocks to specify the trajectory of frame. - Specify Joint Actuation Torque
Use the actuation capability of a joint block to specify the actuation torque on a joint. - Specify Joint Motion Profile
Use the actuation capability of joint blocks to specify the trajectory of a frame. - Use Contact Proxies to Simulate Contact
Use contact proxies to increase the speed and robustness of contact simulations.
Force and Torque Specification
- Actuating and Sensing with Physical Signals
Using physical signals to specify actuation inputs and obtain sensing outputs. - Joint Actuation Limitations
Restrictions and special considerations for models with motion actuation inputs in joint blocks. - Modeling and Measuring System Dynamics
Workflow steps for setting and sensing dynamic quantities such as force, torque, position, and more. - Modeling Gravity
Modeling the effects of uniform gravity, gravitational fields, and individual gravitational forces. Software definition of body boundaries and its impact on gravitational torques. - Specifying Joint Actuation Inputs
Joint actuation modes, motion input handling, and key differences between model assembly and simulation.
Motion, Force, and Torque Sensing
- Force and Torque Sensing
Forces and torques that you can sense and the blocks that you can use to sense them. - Motion Sensing
Motion variables that you can sense and the blocks that you can use to sense them. - Rotational Measurements
Rotational motion variables that you can sense and the blocks that you can use to sense them. - Translational Measurements
Translational variables that you can sense and the blocks that you can use to sense them.
Featured Examples
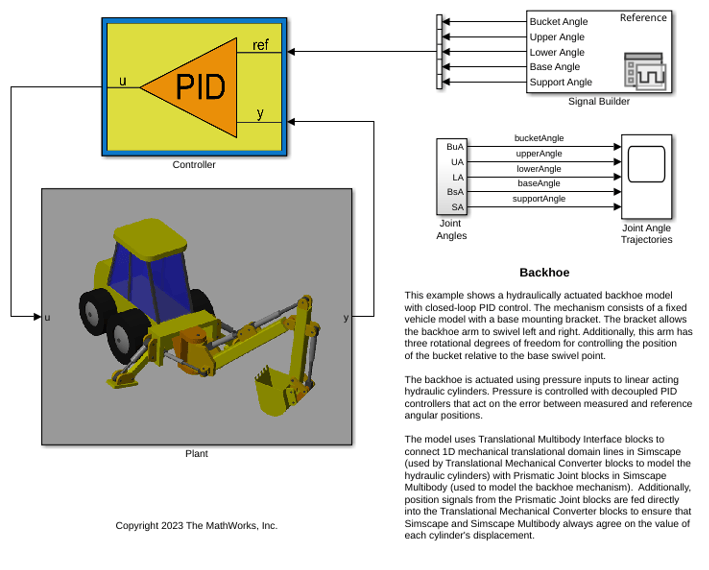
Backhoe
Model a hydraulically actuated backhoe with closed-loop PID control.
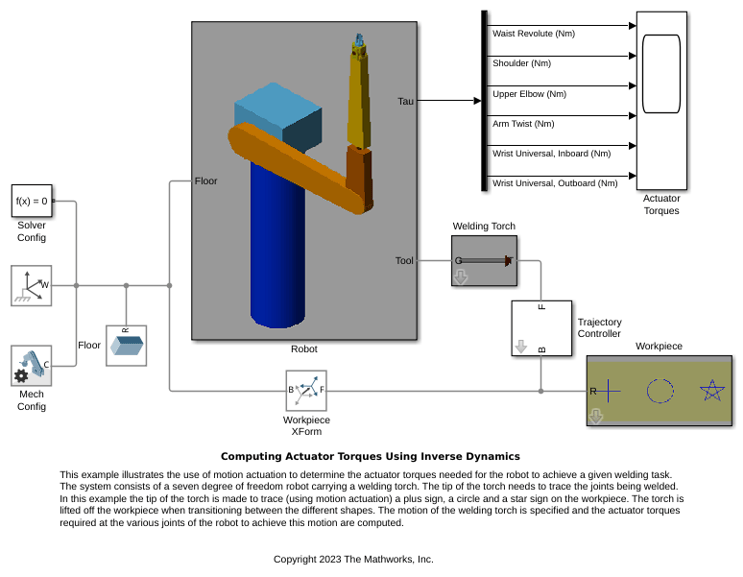
Computing Actuator Torques Using Inverse Dynamics
Illustrates the use of motion actuation to determine the actuator torques needed for the robot to achieve a given welding task. The system consists of a seven degree of freedom robot carrying a welding torch. The tip of the torch needs to trace the joints being welded. In this example the tip of the torch is made to trace (using motion actuation) a plus sign, a circle and a star sign on the workpiece. The torch is lifted off the workpiece when transitioning between the different shapes. The motion of the welding torch is specified and the actuator torques required at the various joints of the robot to achieve this motion is computed.
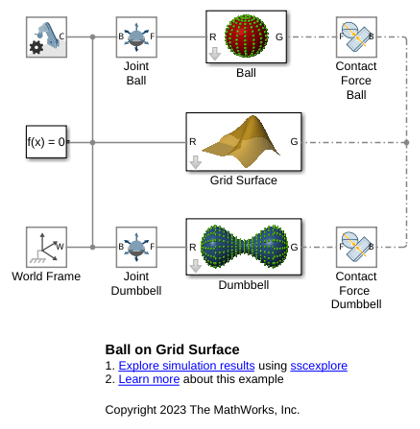
Contact Modeling - Ball on Grid Surface
A ball and dumbbell rolling down on an L-shaped surface. Grid Surface block is used to generate the L-shaped membrane. Point Cloud blocks are used to model the contact between the ball/dumbbell and the surface. The number of point blocks can be controlled by varying the point cloud density. This example demonstrates the capabilities of Grid Surface and Point Cloud blocks to model contacts between complex shaped bodies.
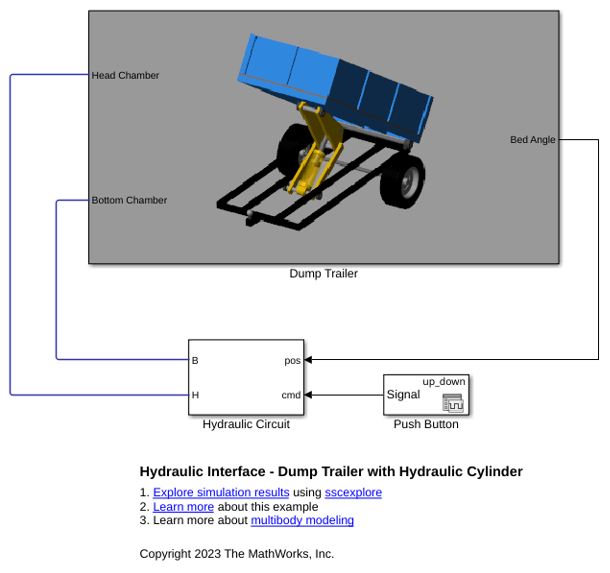
Hydraulic Interface - Dump Trailer with Hydraulic Cylinder
A dump trailer powered by a double-acting hydraulic cylinder. The cylinder actuates a scissor hoist mechanism that raises and lowers the dump bed. The model provides an example of how to interface Simscape™ Multibody™ joints with Simscape components that have mechanical domain ports.
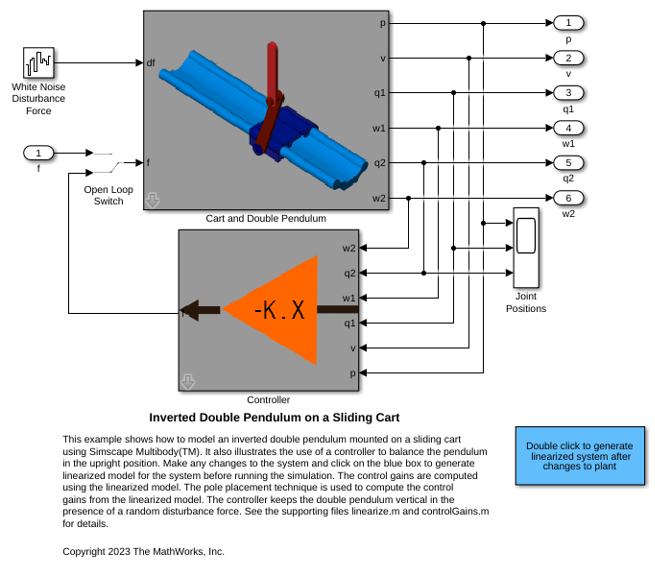
Inverted Double Pendulum on a Sliding Cart
Model an inverted double pendulum mounted on a sliding cart using Simscape™ Multibody™. It also illustrates the use of a controller to balance the pendulum in the upright position. Make any changes to the system and click on the blue box to generate a linearized model for the system before running the simulation. The control gains are computed using the linearized model. The pole placement technique is used to compute the control gains from the linearized model. The controller keeps the double pendulum vertical in the presence of a random disturbance force. See the supporting files linearize.m and controlGains.m for details.
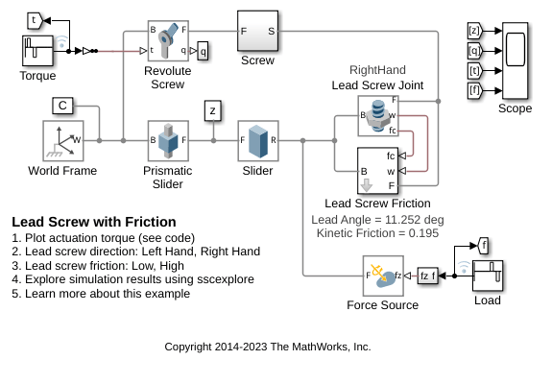
Lead Screw with Friction
Models a lead screw with friction. The constraint force in the lead screw is measured and used to calculate the friction torque within the lead screw. A continuous stick-slip friction model is used to determine the coefficient of friction based on the relative rotational speed of the two parts connected by the lead screw.
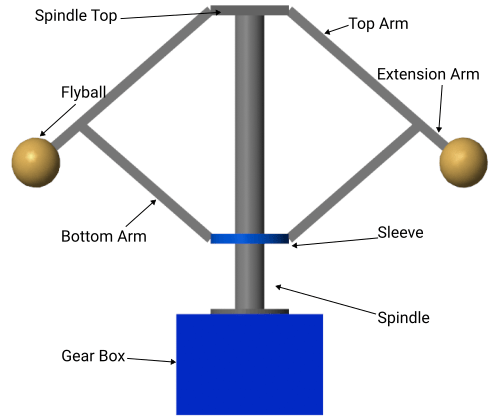
Measure Inertial Properties of Multibody Systems
Measure the inertial properties, such as mass
and center of mass, of a group of bodies or an entire mechanism by using the
Inertia Sensor block.
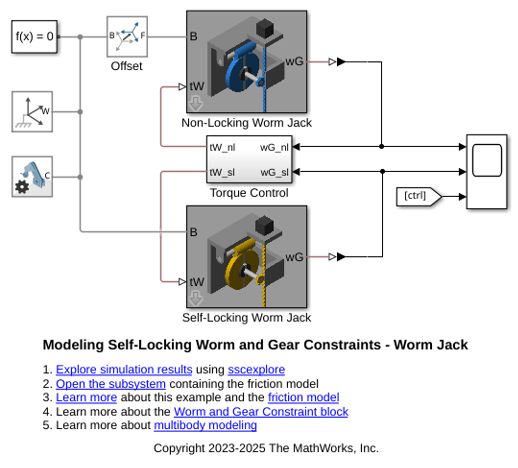
Modeling Self-Locking Worm and Gear Constraints - Worm Jack
Models a self-locking worm and gear constraint. The model shows a mechanical jack driven by a torque applied to a worm. The model includes two worm jack subsystems identical in every sense except for the value of the worm lead angle. Both subsystems have friction models applied to their Worm and Gear Constraint blocks.
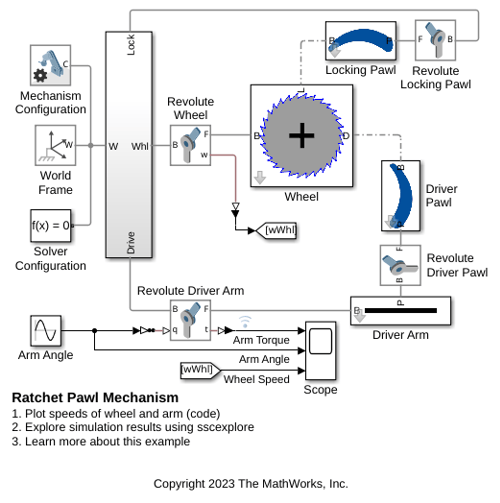
Ratchet Pawl Mechanism
Models a ratchet with a locking pawl. The arm pushes the driving pawl to rotate the ratchet wheel. The locking pawl holds the ratchet wheel in place while the arm reverses direction. Planar contact modeling geometry is used to streamline computation.
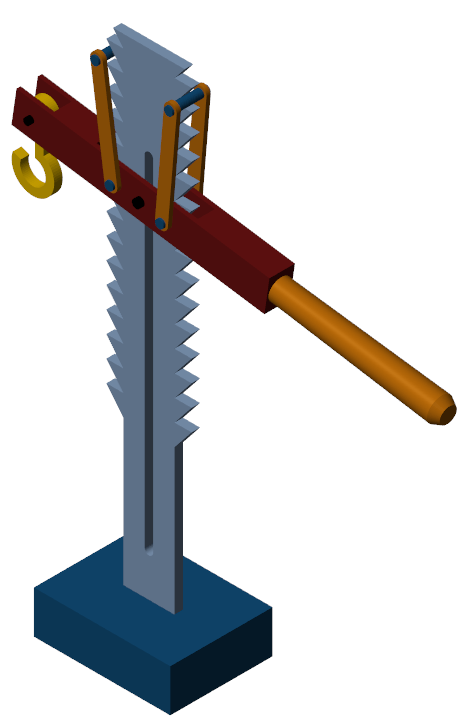
Ratchet Lifter
Models a ratchet lifter and demonstrates how to use contact proxies for contact problems that involve complex geometries.
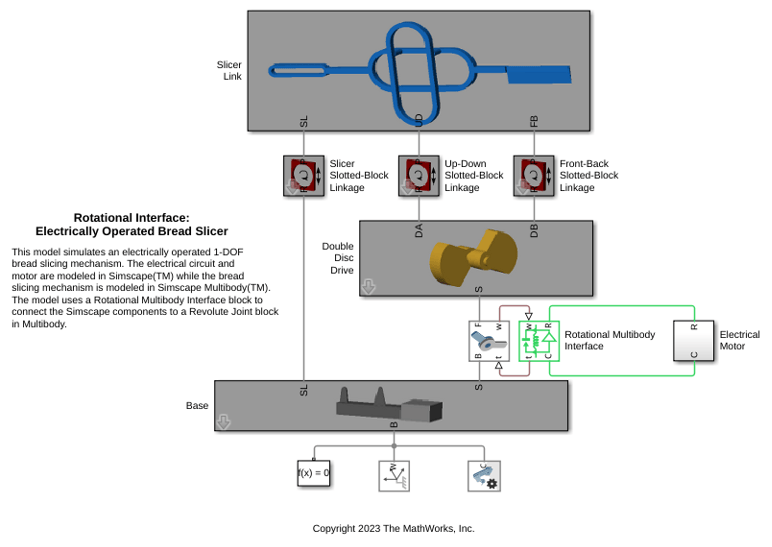
Rotational Interface: Electrically Operated Bread Slicer
This model simulates an electrically operated 1-DOF bread slicing mechanism. The electrical circuit and motor are modeled in Simscape™ while the bread slicing mechanism is modeled in Simscape Multibody™. The model uses a Rotational Multibody Interface block to connect the Simscape components to a Revolute Joint block in Multibody.
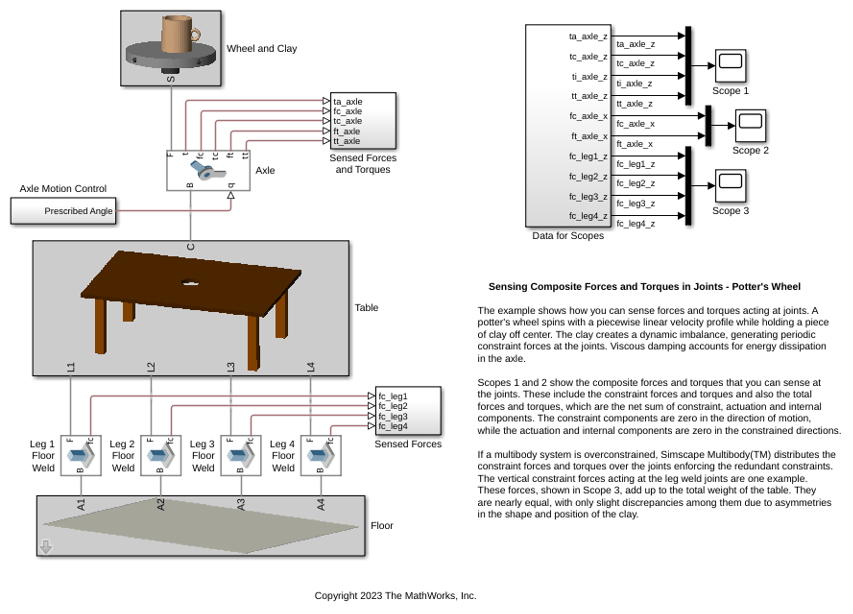
Sensing Composite Forces and Torques in Joints - Potter's Wheel
The example shows how you can sense forces and torques acting at joints. A potter's wheel spins with a piecewise linear velocity profile while holding a piece of clay off center. The clay creates a dynamic imbalance, generating periodic constraint forces at the joints. Viscous damping accounts for energy dissipation in the axle.
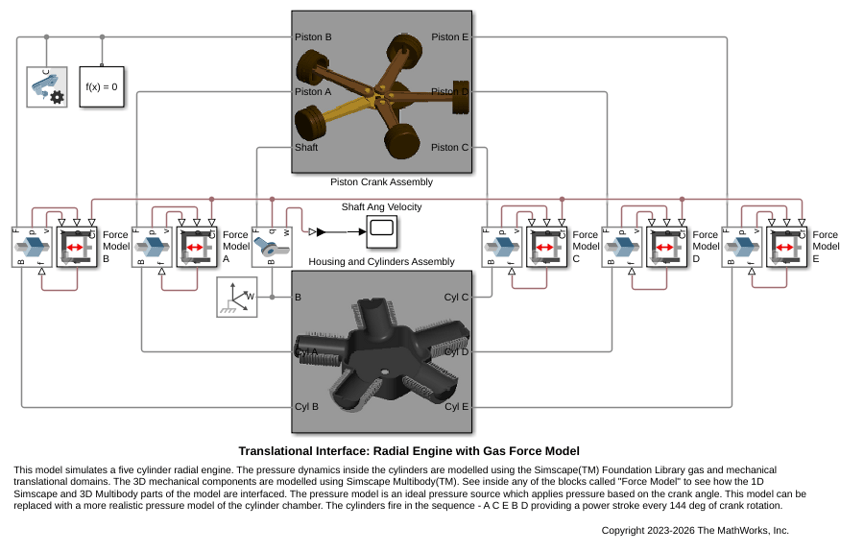
Translational Interface: Radial Engine with Gas Force Model
This model simulates a five cylinder radial engine. The pressure dynamics inside the cylinders are modeled using the Simscape™ Foundation Library gas and mechanical translational domains. The 3D mechanical components are modeled using Simscape Multibody™. See inside any of the blocks called "Force Model" to see how the 1D Simscape and 3D Multibody parts of the model are interfaced. The pressure model is an ideal pressure source which applies pressure based on the crank angle. This model can be replaced with a more realistic pressure model of the cylinder chamber. The cylinders fire in the sequence - A C E B D providing a power stroke every 144 deg of crank rotation.
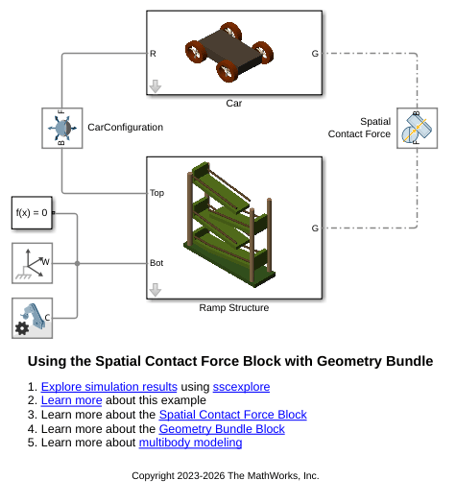
Using the Spatial Contact Force Block with Geometry Bundle
A toy bumper car traveling down a series of ramps while undergoing intermittent collisions. A Spatial Contact Force block is used with Geometry Bundle blocks to model the friction and normal forces between every pair of geometries that may potentially come into contact during the simulation (e.g., between one of the car's wheels and a railing). The Spatial Contact Force block is able to generate brief high-impact contact forces to model collisions, as well as sustained contact forces to model rolling and sliding. The Geometry Bundle blocks group together geometries so that the connected Spatial Contact Force block can generate forces for multiple pairs of geometries.
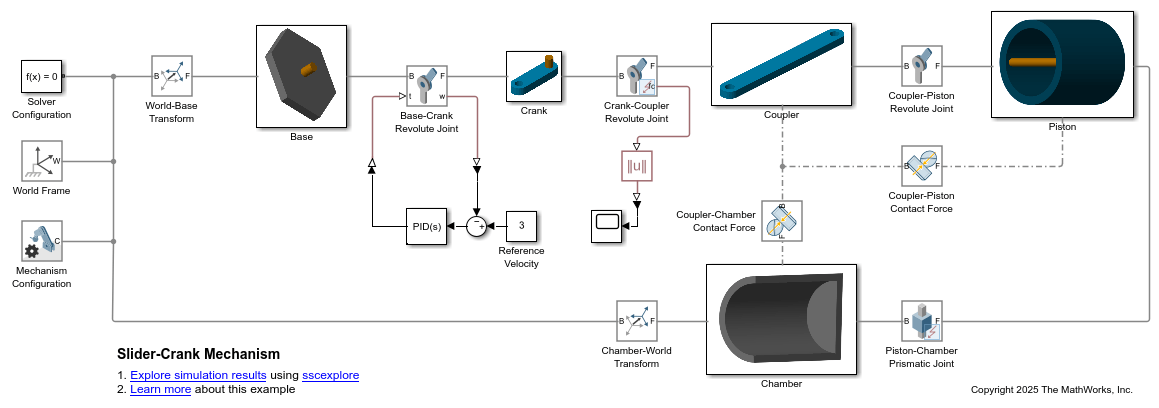
Model Joint Mode Faults - Slider-Crank Mechanism
Demonstrates how to model joint mode faults in a slider-crank mechanism using Simscape™ Multibody™.
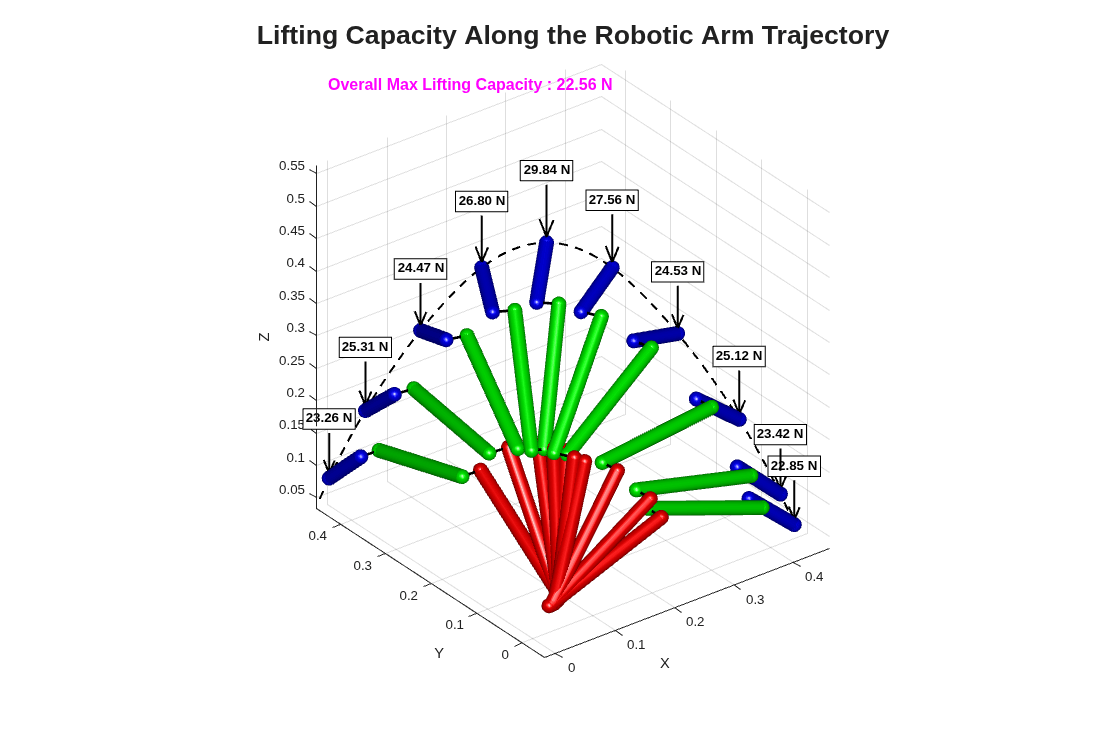
Dynamics Analysis of a Robotic Arm in MATLAB
Demonstrates a workflow for dynamics analysis of a robotic arm in MATLAB.
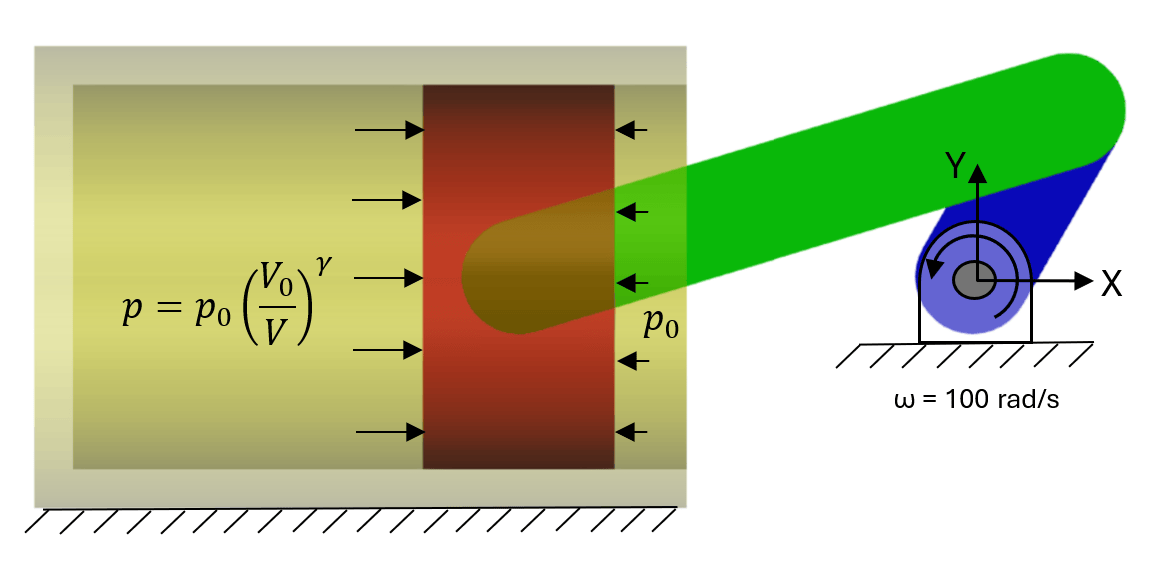
Analyze Joint Constraint Forces in a Slider-Crank Mechanism Using componentResults Method in MATLAB
Demonstrates how to compute joint constraint forces in a slider-crank mechanism.

